Research ↗
Investigate robotics, networked control, and aerial and ground autonomy.
Howard University · College of Engineering and Architecture
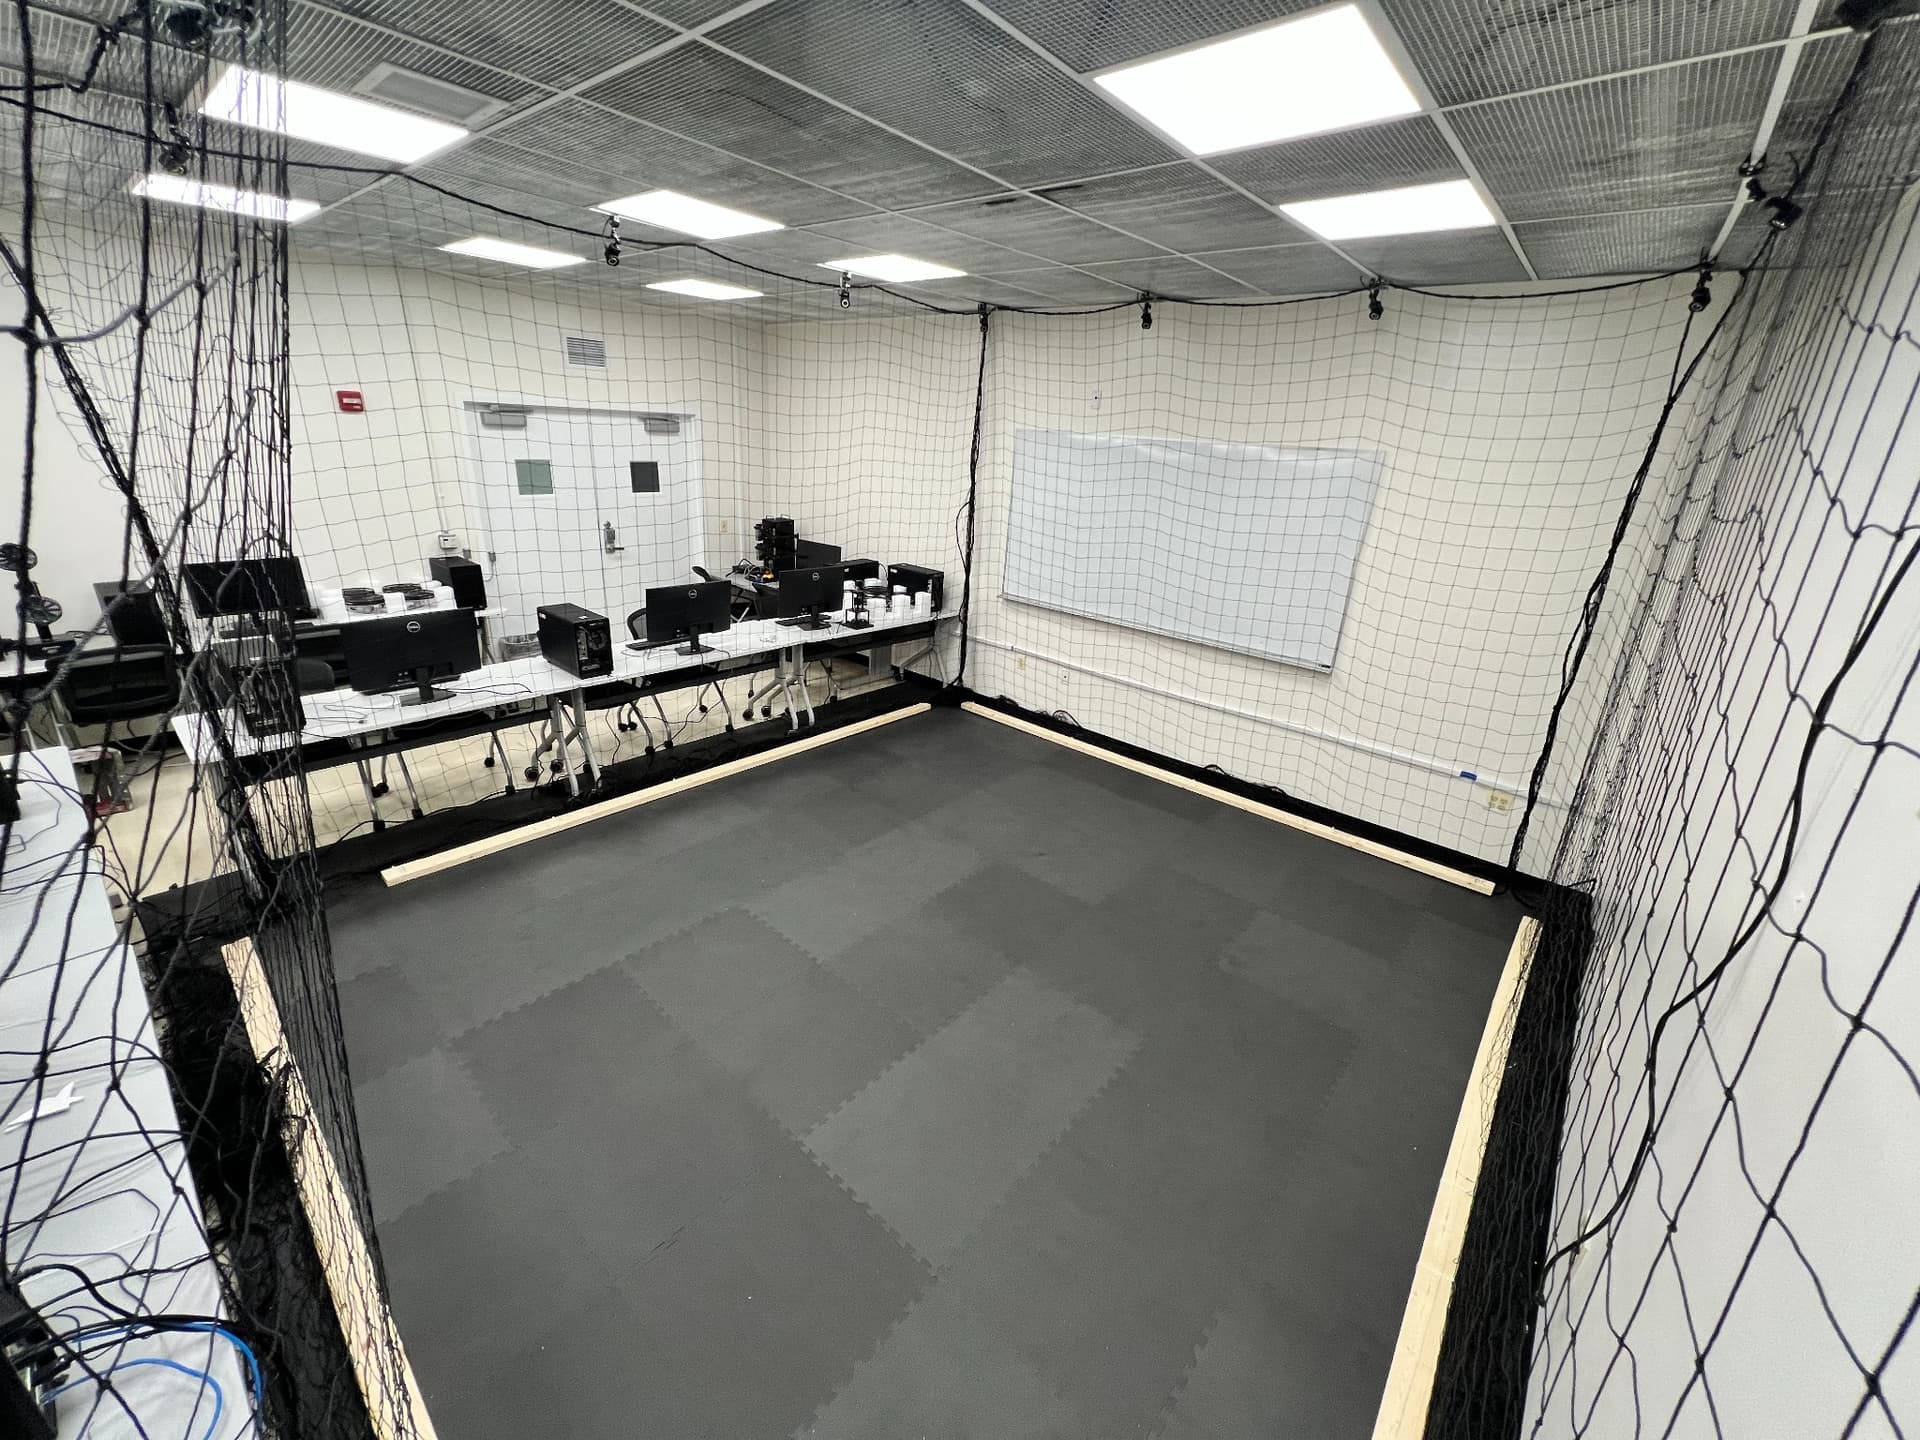
The Autonomous Vehicle, Robotics & Control Laboratory is a shared resource for teaching, research, senior design, and outreach at Howard University, within the Department of Electrical Engineering and Computer Science.
B20, Mackey Building · Directed by Fadel Lashhab, Ph.D.


STEM educators · Howard University
Explore a three-week research experience in robotics and automation: two weeks of virtual learning, followed by one week in the AVRC Laboratory.
Participant support of up to $5,900 includes stipends, housing, and transportation, subject to eligibility and program requirements.
2027 planning: applications are not yet open. Dates are proposed.
A shared environment for students, faculty, research teams, and STEM educators across engineering and computing.
Investigate robotics, networked control, and aerial and ground autonomy.
Connect computing and engineering concepts to measurements, models, and physical systems.
Develop a scoped project with a faculty mentor and a repeatable test plan.
Explore technical videos, code, documentation, and lab materials.
Prepare for supervised work with shared lab orientation and safety resources.
Explore research experiences and classroom integration for STEM educators.
AVRC connects software and mathematical models with physical systems. Sensors measure the system’s response; computation uses measurements and models to determine control actions. Communication links exchange data and commands, and actuators produce the physical response. Together, these elements form a feedback-control system.
Across the platforms, sensing includes encoders, tachometers, accelerometers, LiDAR, RGB cameras, and depth cameras. The available measurements and motor interfaces depend on the equipment and experiment.
MATLAB and Simulink support modeling, simulation, and controller development. QUARC provides real-time deployment, hardware interfacing, and communication for supported targets. Python and supported ROS/ROS 2 interfaces enable programming and system integration.
QLabs digital twins and assigned simulation models allow students to prepare remotely before supervised hardware work. Access depends on the assigned software licenses and platform configuration. Howard faculty and students arrange lab sessions through coordinated scheduling, orientation, and platform-specific training.
The same practical sequence connects a first lab exercise with a longer research or design project.
Choose a question, learning objective, and measurable outcome.
Explore a model or digital twin and document a baseline.
Test on hardware after orientation and approval.
Compare evidence, explain limitations, and improve the design.
Control, autonomous systems, robotics, and artificial intelligence share physical platforms and a progression from virtual preparation to supervised experiments.
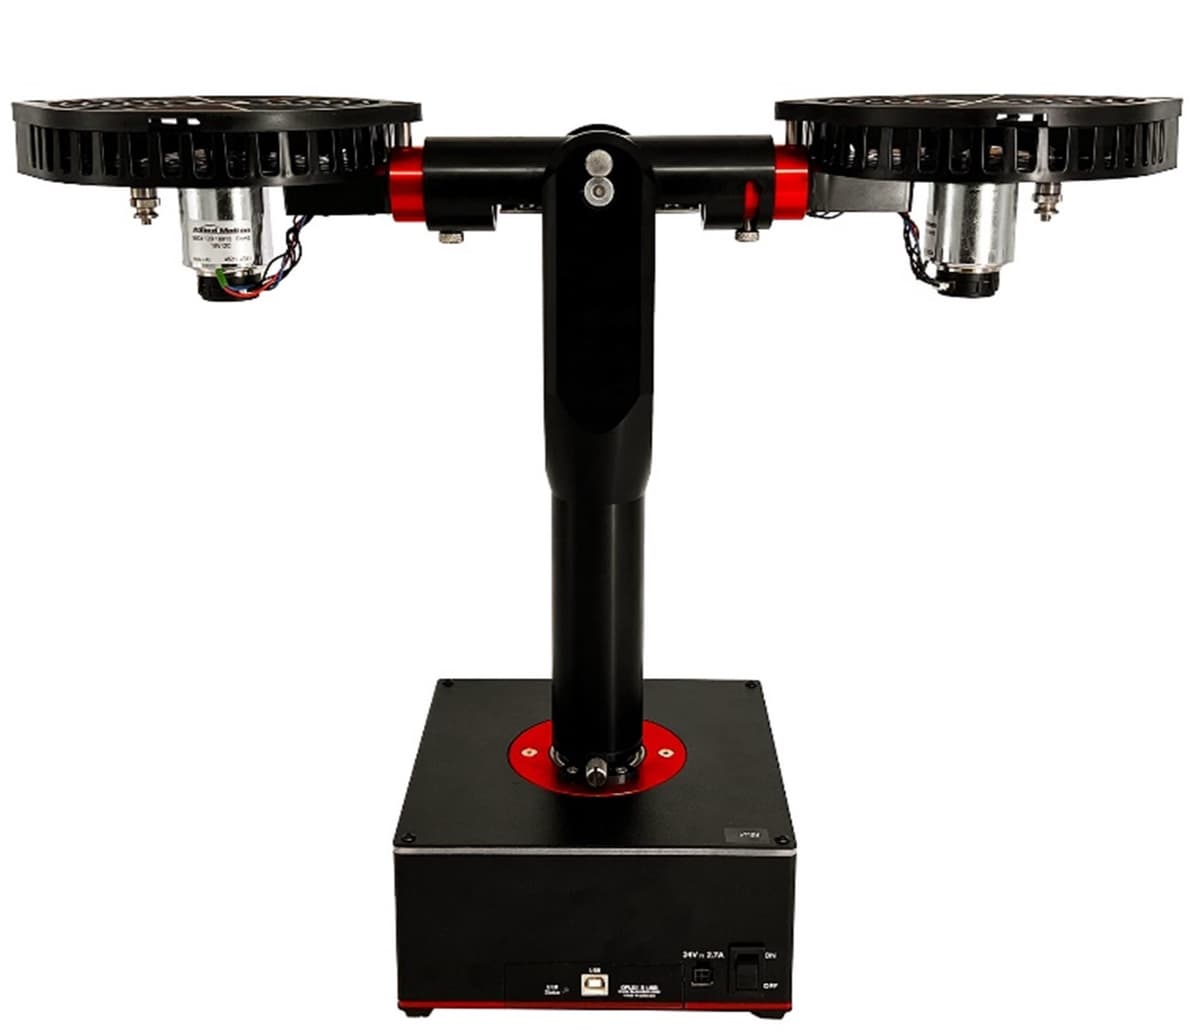
QUBE-Servo 3, Aero 2, and 3 DOF Hover for modeling, instrumentation, and feedback control.
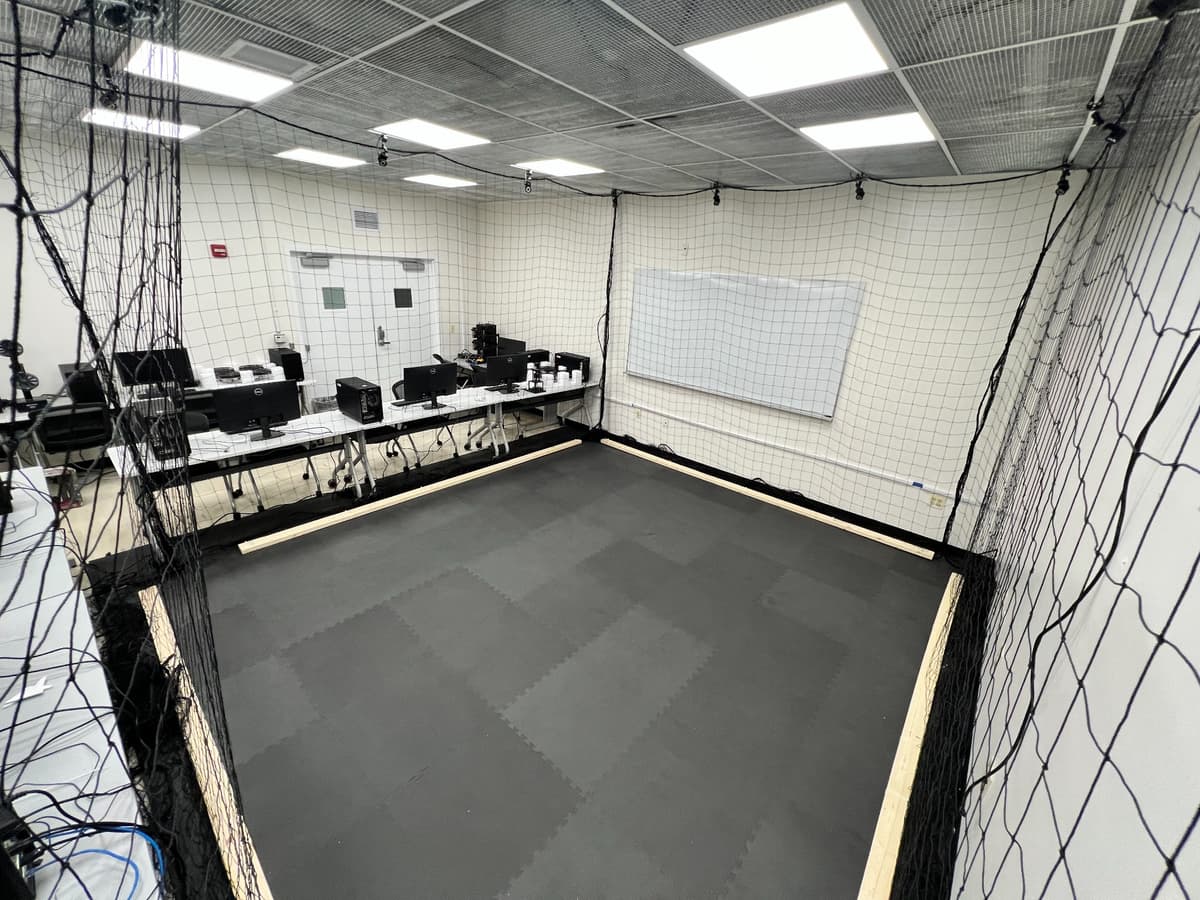
QDrone 2 and QBot Platform, supported by 12 OptiTrack cameras and a ground-control environment.
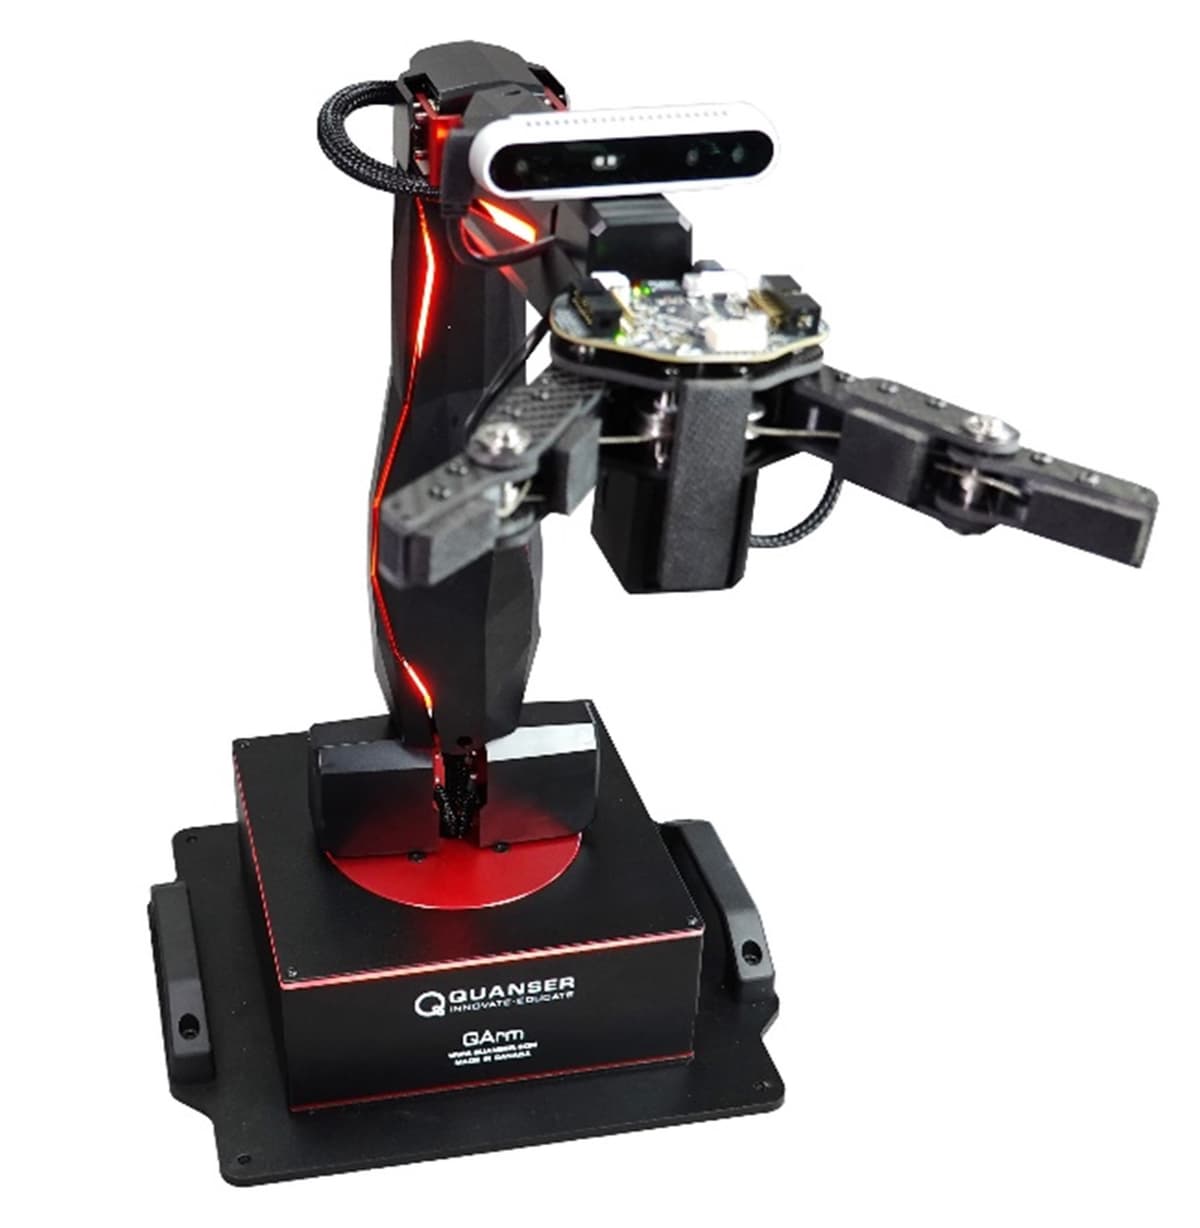
QArm, QArm Mini, and HD² haptics for manipulation, sensing, and human interaction.
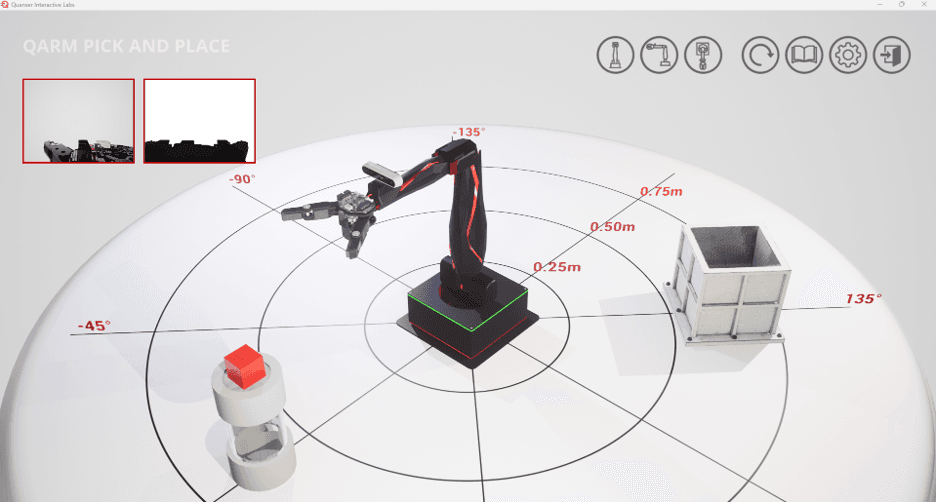
Machine learning, visual perception, and proposed cooperative-robotics projects using shared QBot Platform, QDrone 2, and QArm resources.
RAOP connects a two-week virtual phase with a one-week on-site experience at Howard University. Explore the 2026 cycle, educator guide, blank assessments, photos, and reflections.
2026 summer cycle complete · Explore RAOP 2027 planning →
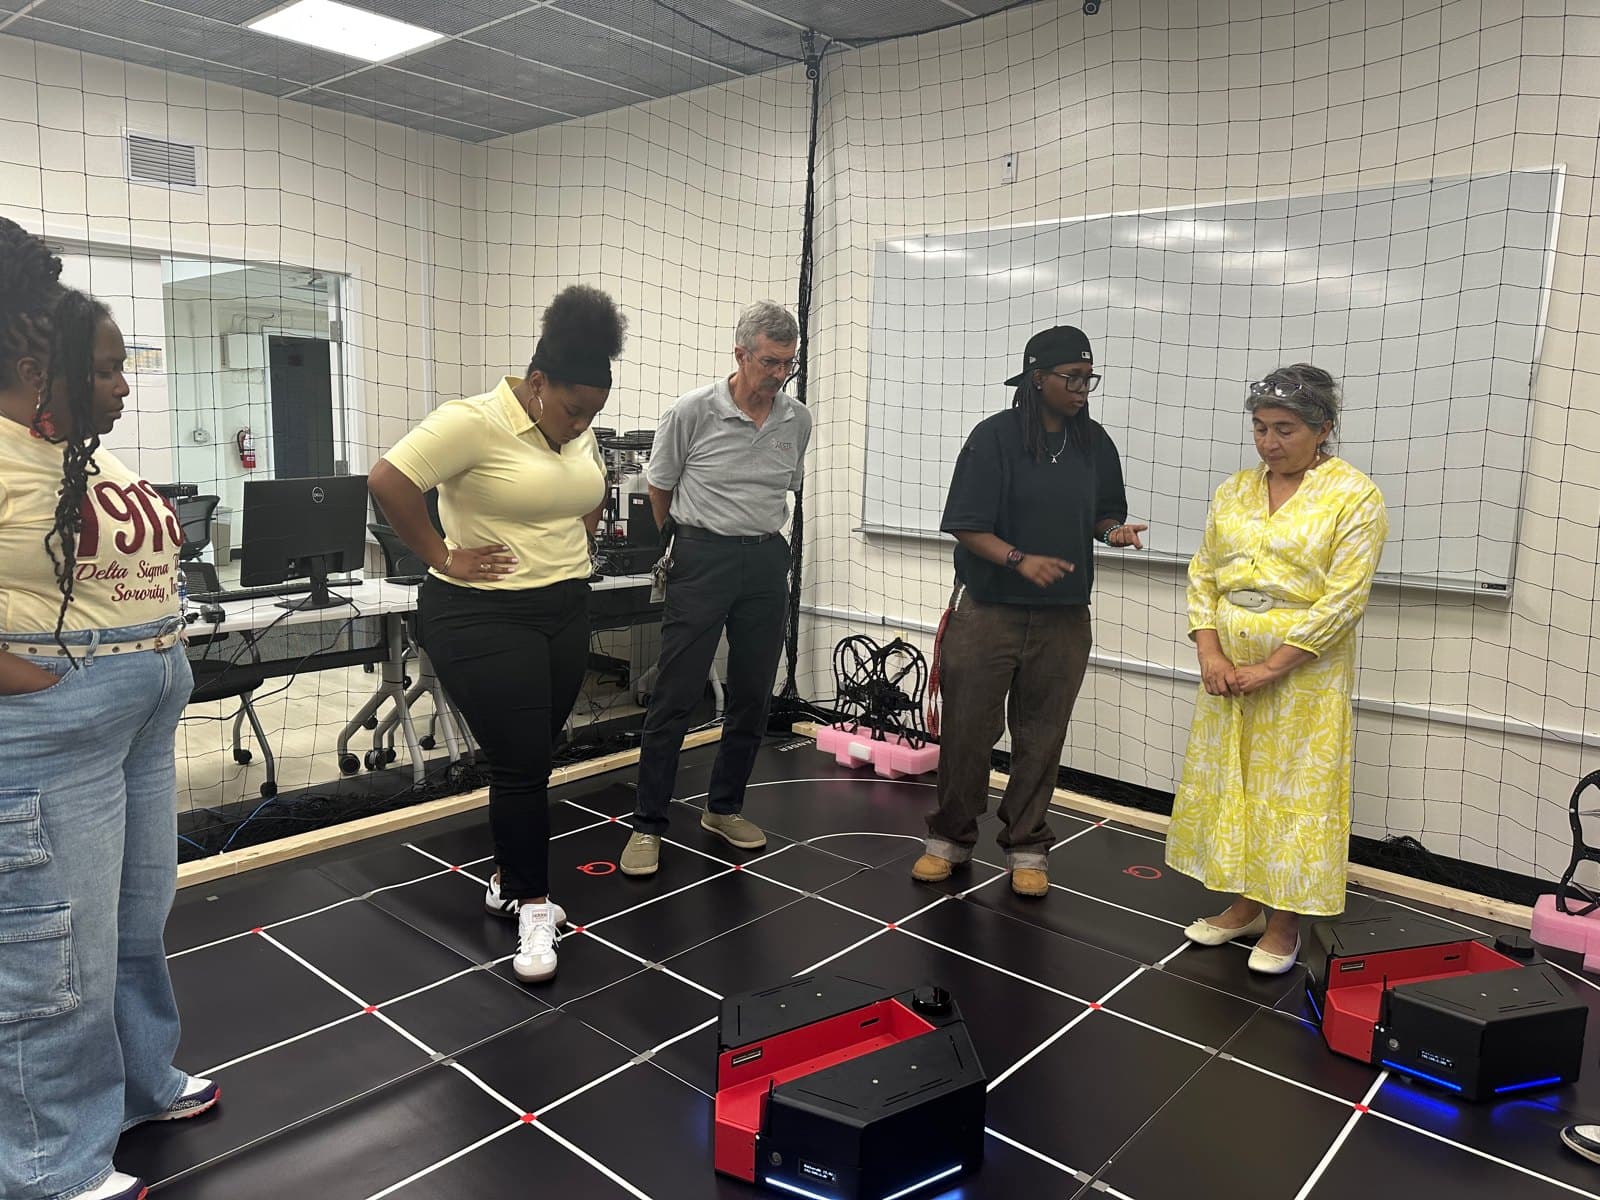
Discuss the learning goals, platform, team size, and supervision needed for a practical lab experience.