AVRC Laboratory · 01 · Model, measure, regulate
Control Systems
Progress from a single-motor servo to coupled rotor dynamics and multivariable attitude control.
Questions to investigate
Feedback, stability, and transient response
State-space control and actuator constraints
Explore each platform
Open a guide for component explanations, an annotated equipment figure, learning activities, and official technical resources.
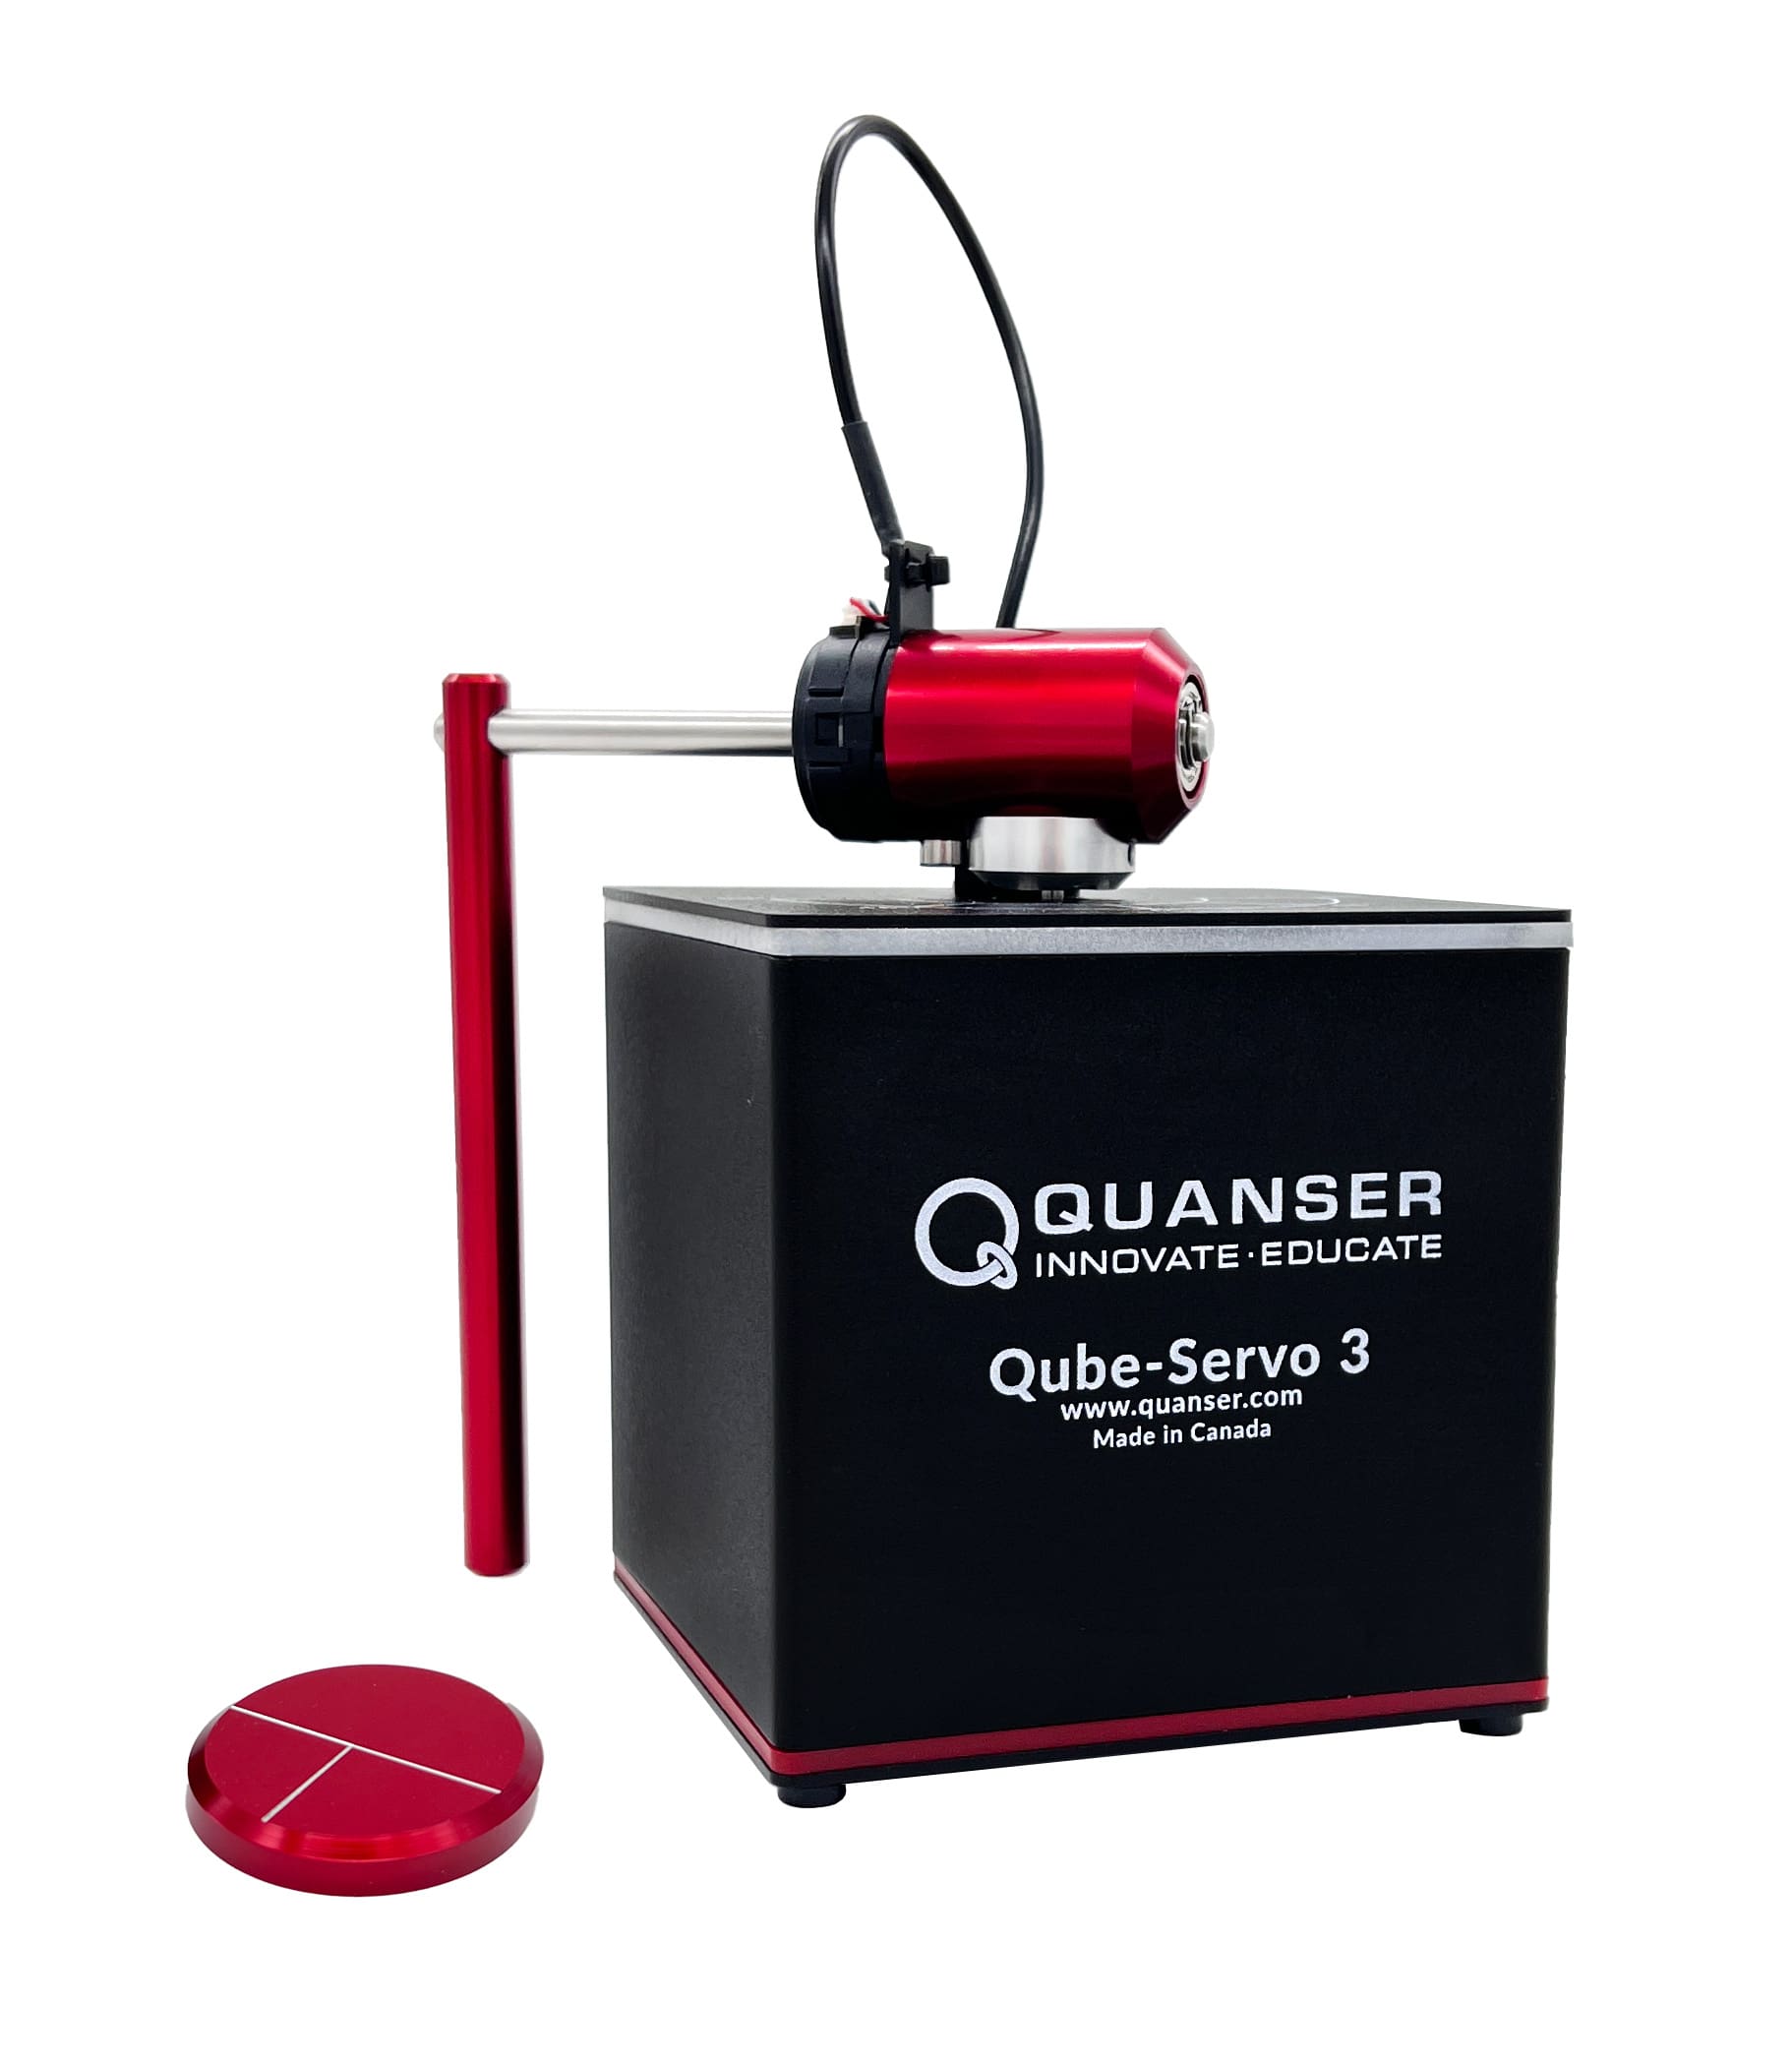 Rotary servo · inverted pendulum
QUBE-Servo 3 →
A compact introduction to modeling, sensing, and feedback.
Photograph: Quanser
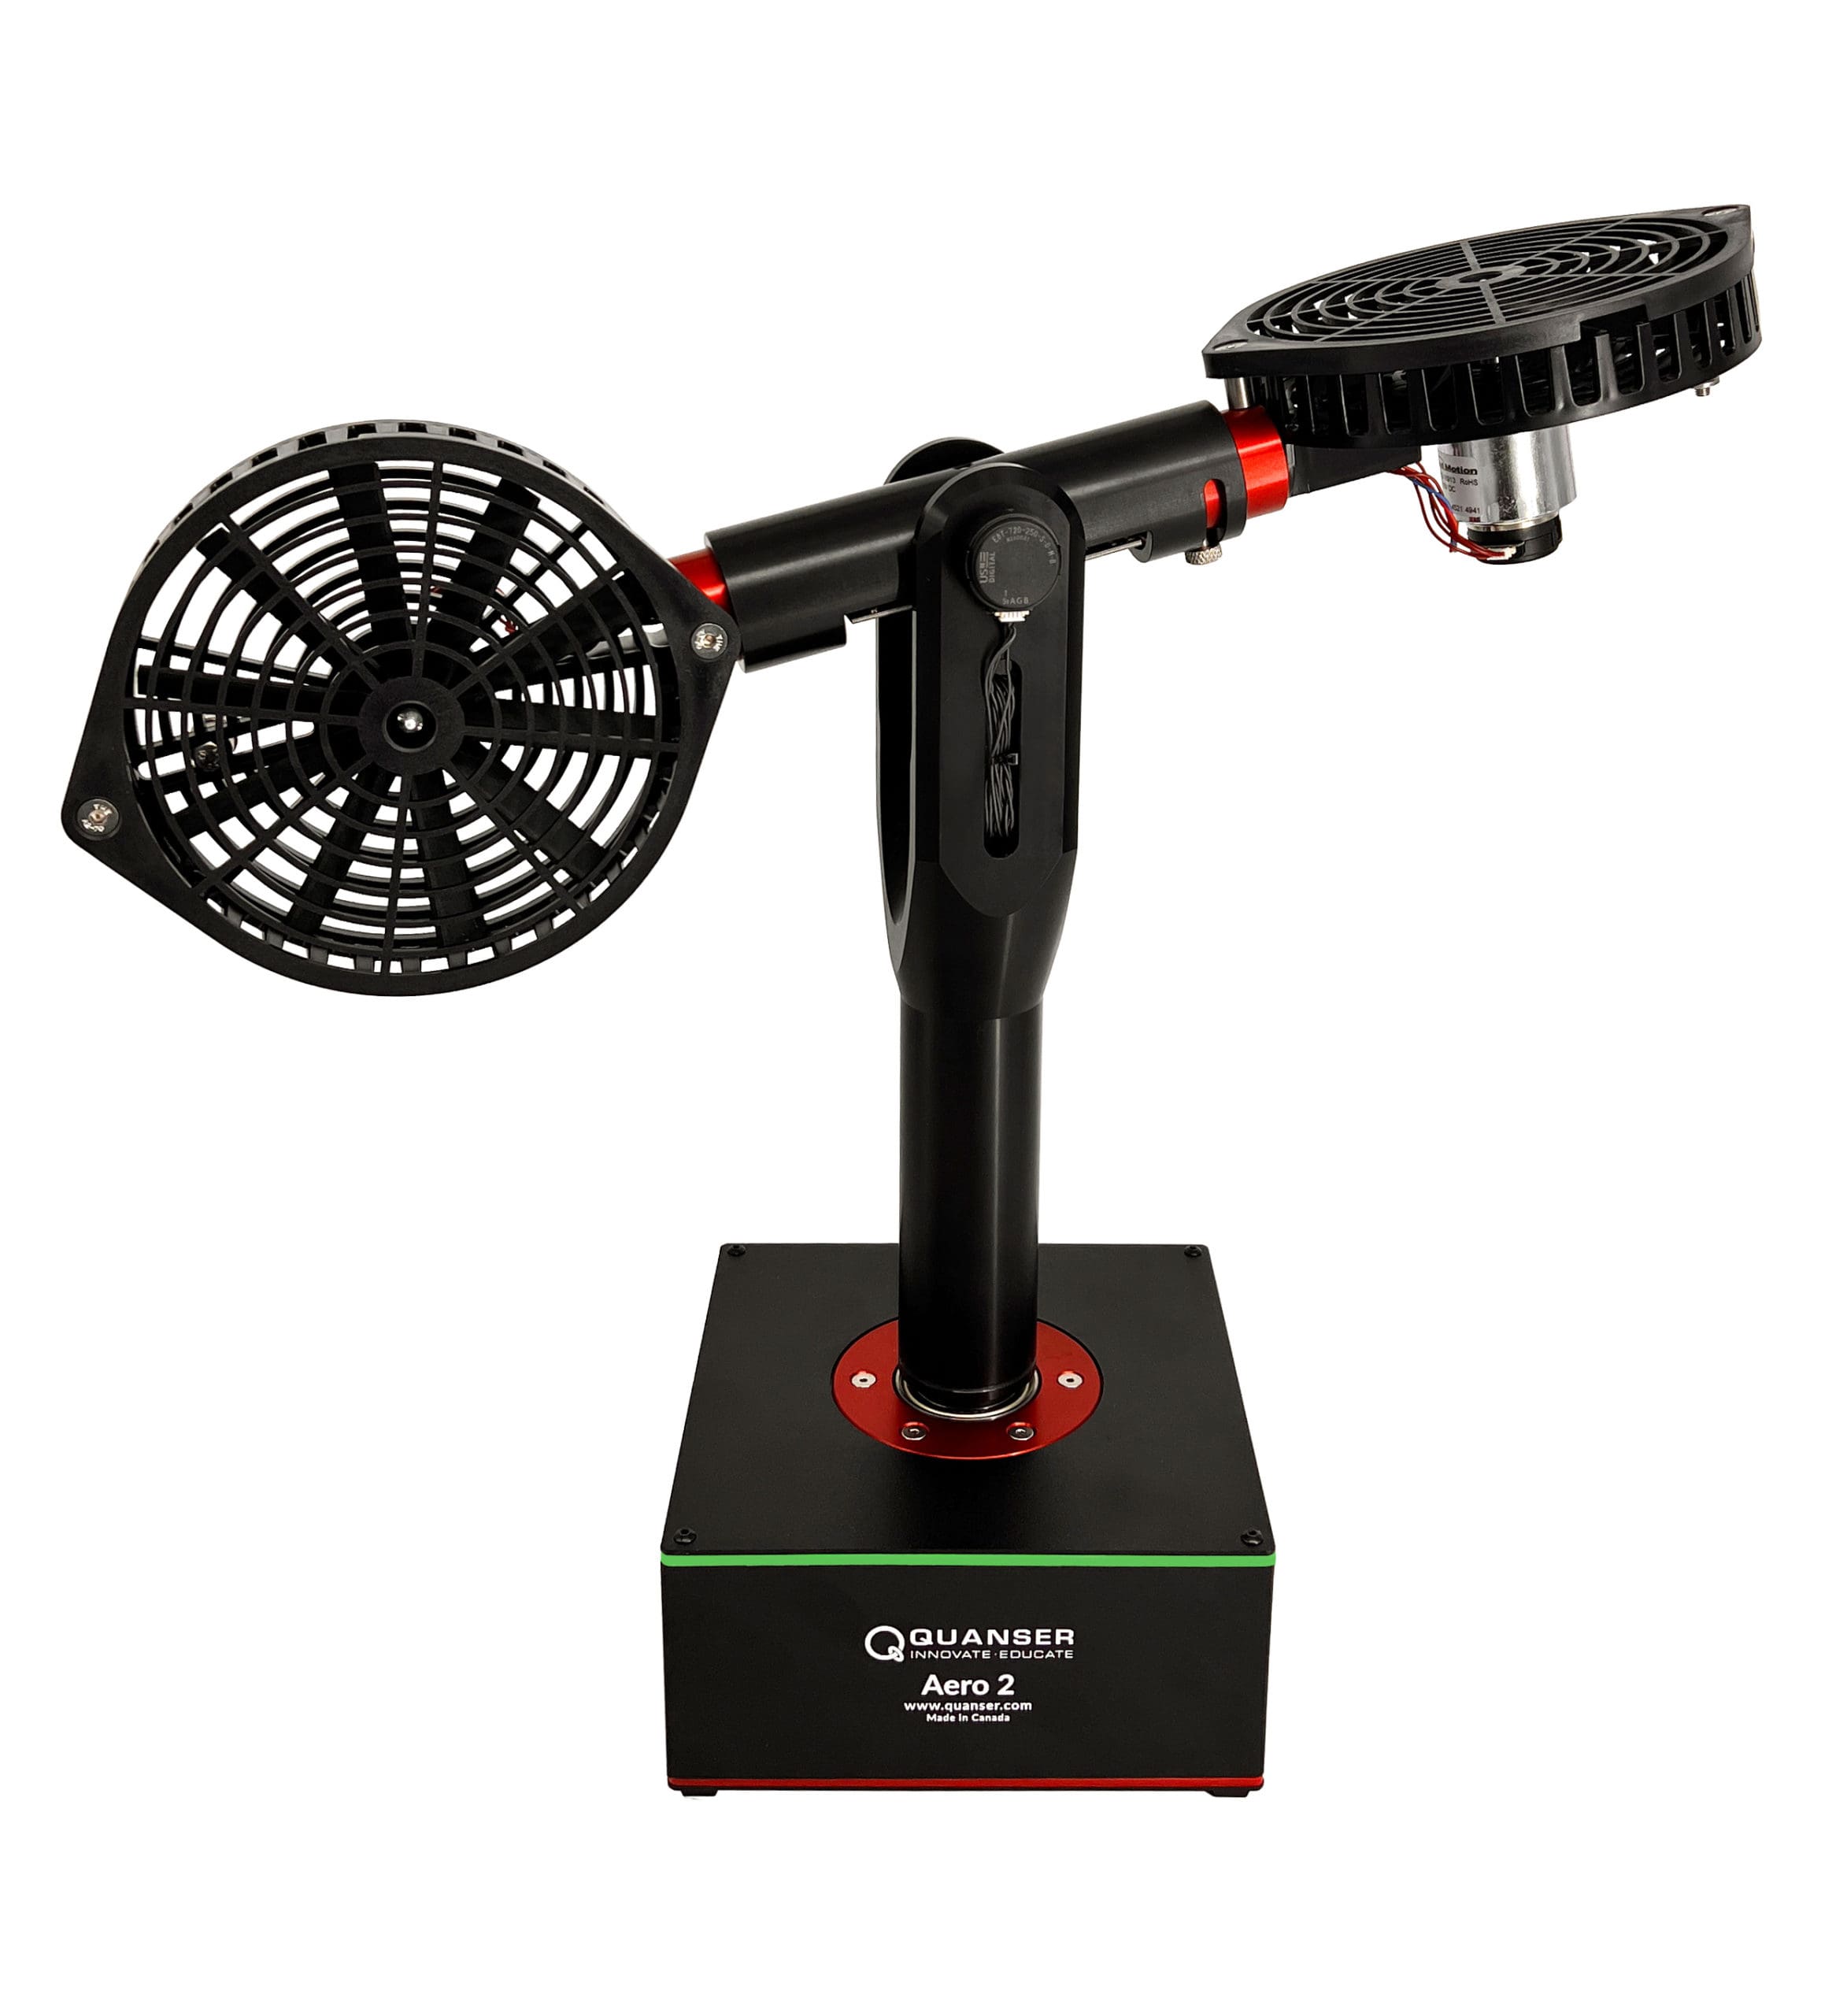 Two motors · pitch & yaw
Aero 2 →
Explore coupled pitch and yaw through a configurable twin-rotor system.
Photograph: Quanser
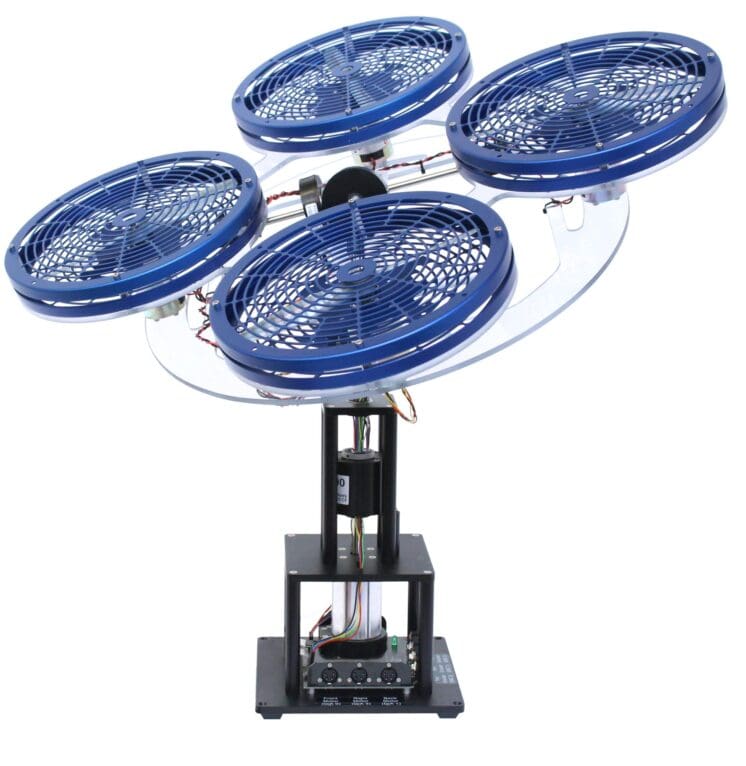 Four motors · three angular outputs
3 DOF Hover →
Study quadrotor attitude dynamics on a fixed laboratory rig.
Photograph: Quanser
Bring this unit into your course or project
Faculty and students across Howard’s computing and engineering programs can discuss course, research, VIP, capstone, and senior design activities with AVRC. The instructor and faculty mentor define the learning objectives, experiment, preparation, and assessment.
Bring your course or project to the lab.
Discuss the learning goals, platform, team size, and supervision needed for a practical lab experience.